Training project
DESIGN & MAKE – MECANUM ROVER
From parametric CAD model to a remote-controlled omnidirectional vehicle
Request a quoteOpen 3D model in Autodesk Fusion
- Original Fusion model
- Learning tasks in the MLS learning system
- Parts
- 9
- Length
- 150mm
- Height
- 52.5mm
- Mass
- 490g
-
Workshop Design & Make · Mecanum rover
DESIGN & MAKE.MECANUM ROVER.
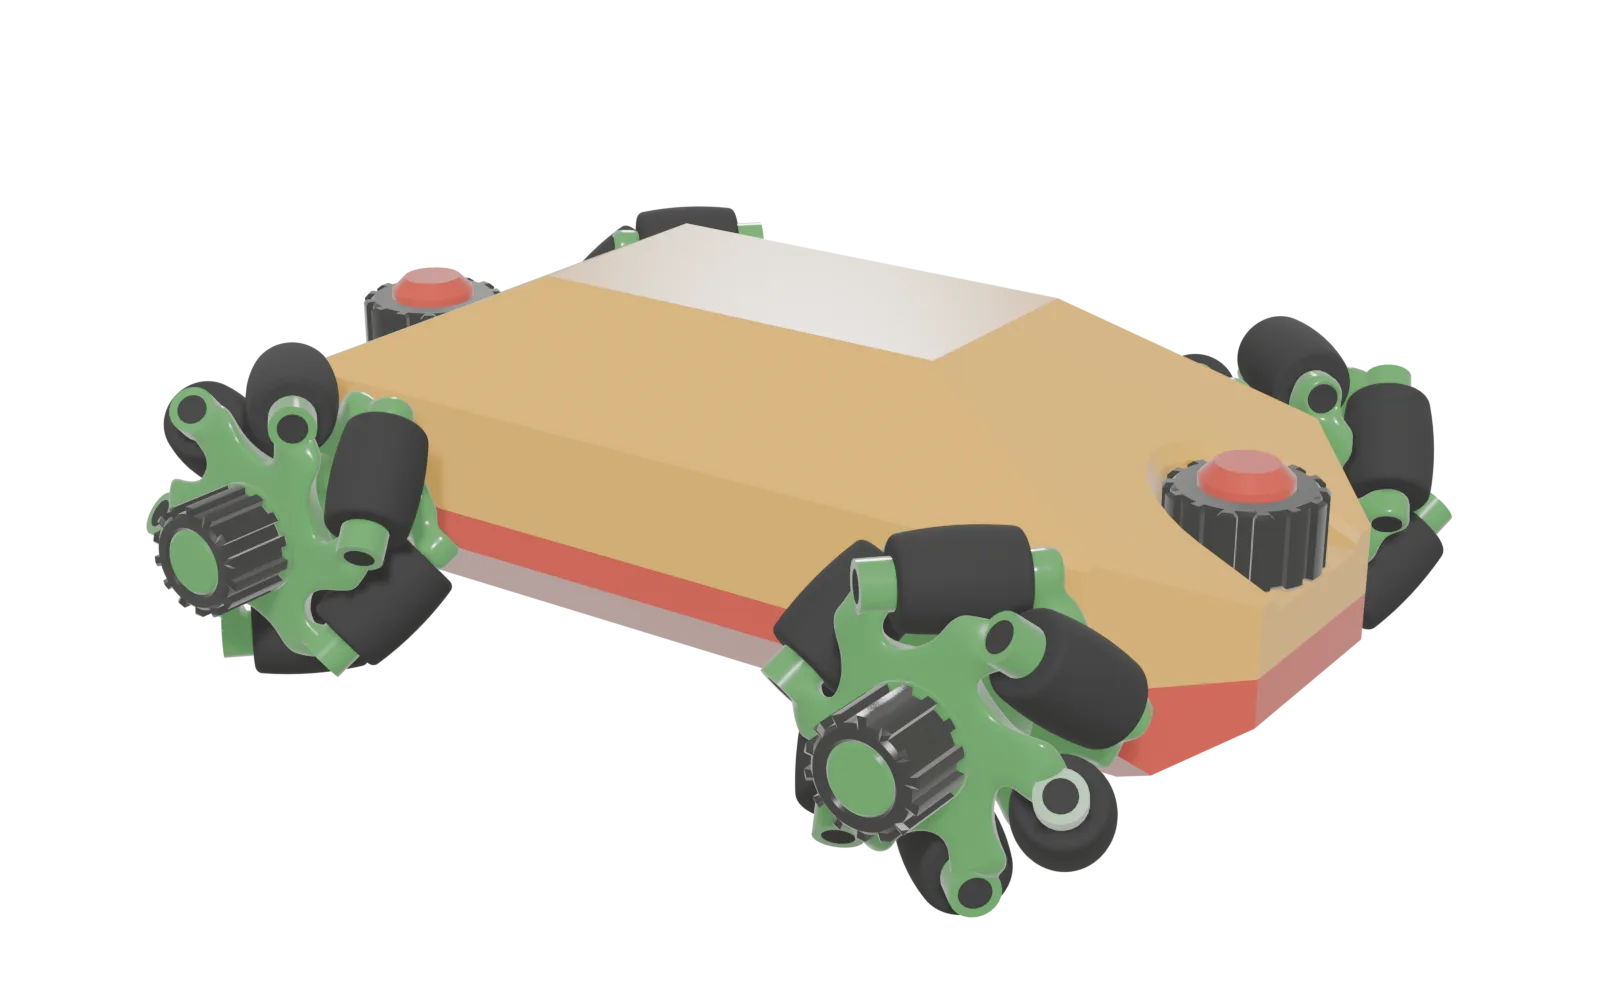
From the parametric CAD model to a remote-controlled, omnidirectional vehicle. What you see is our own design model from Fusion: 217 bodies, about 16 centimetres long.
-
01 / 05
OPENED UP.ALL INSIDE.
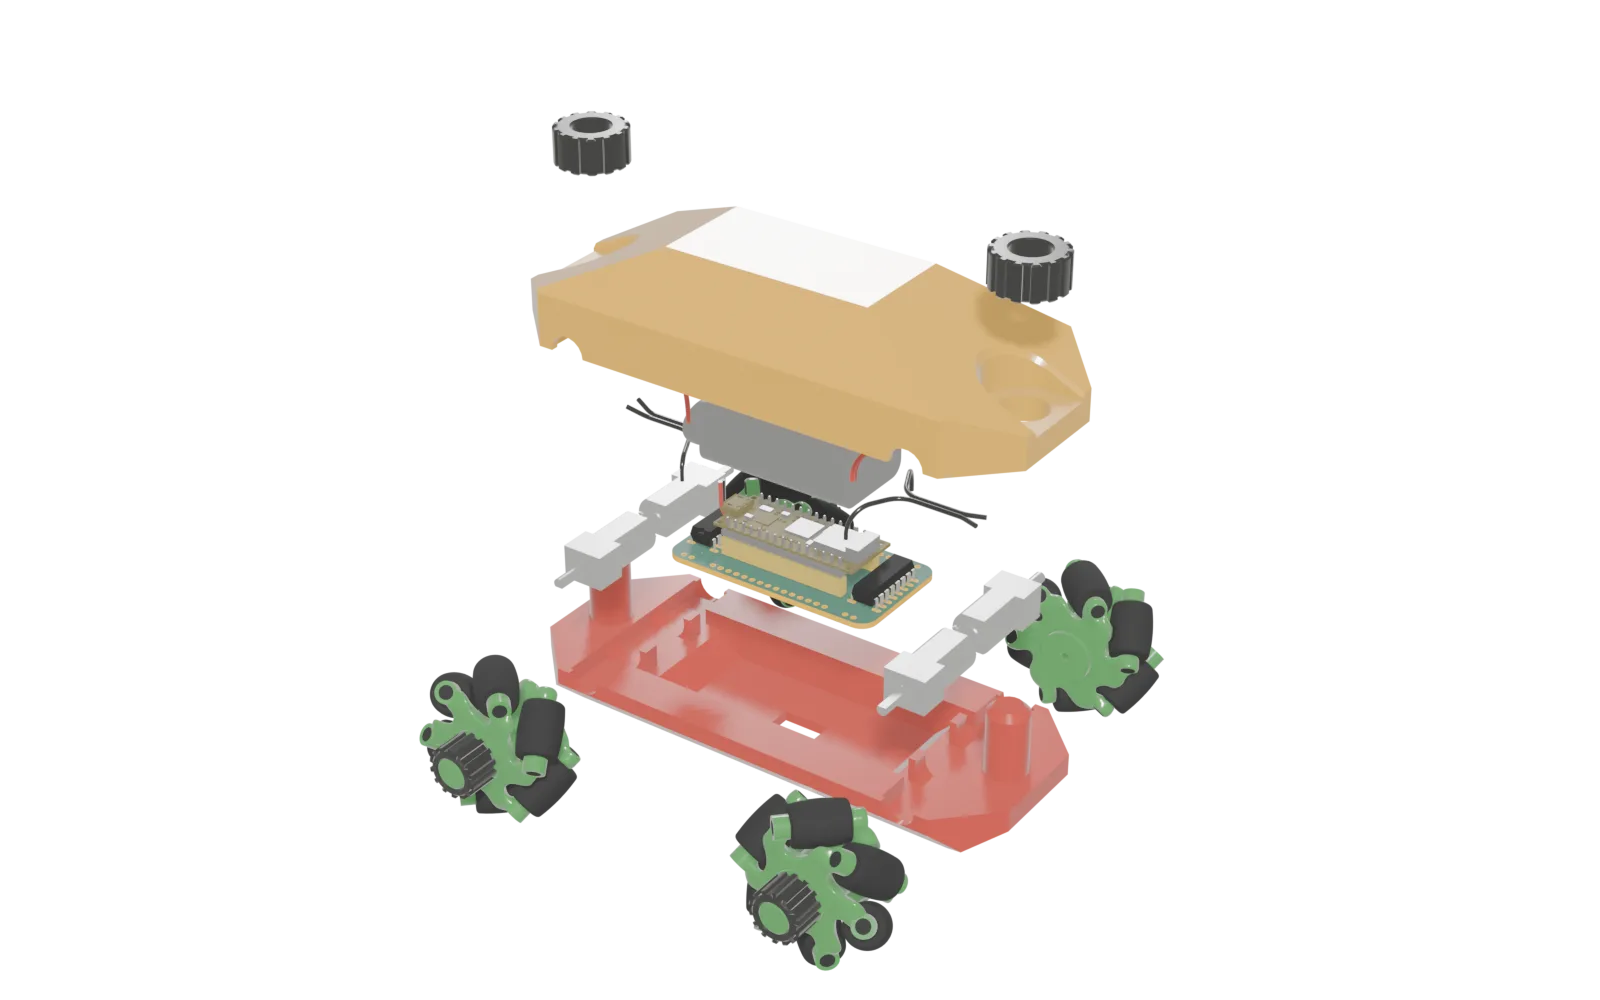
Base, roof, four Mecanum wheels, four DC motors, the board and the 9 V battery. Housing and wheels come from the 3D printer, printed in PLA.
What this part involves
- Base sketch with centre-point rectangle and switch cut-out
- Cut the recess for the circuit board
- Sketch the motor profile, one side only
- Cut the motor profile and add the 7 mm chamfer
-
02 / 05
THE MECANUM WHEEL.SET AT AN ANGLE.
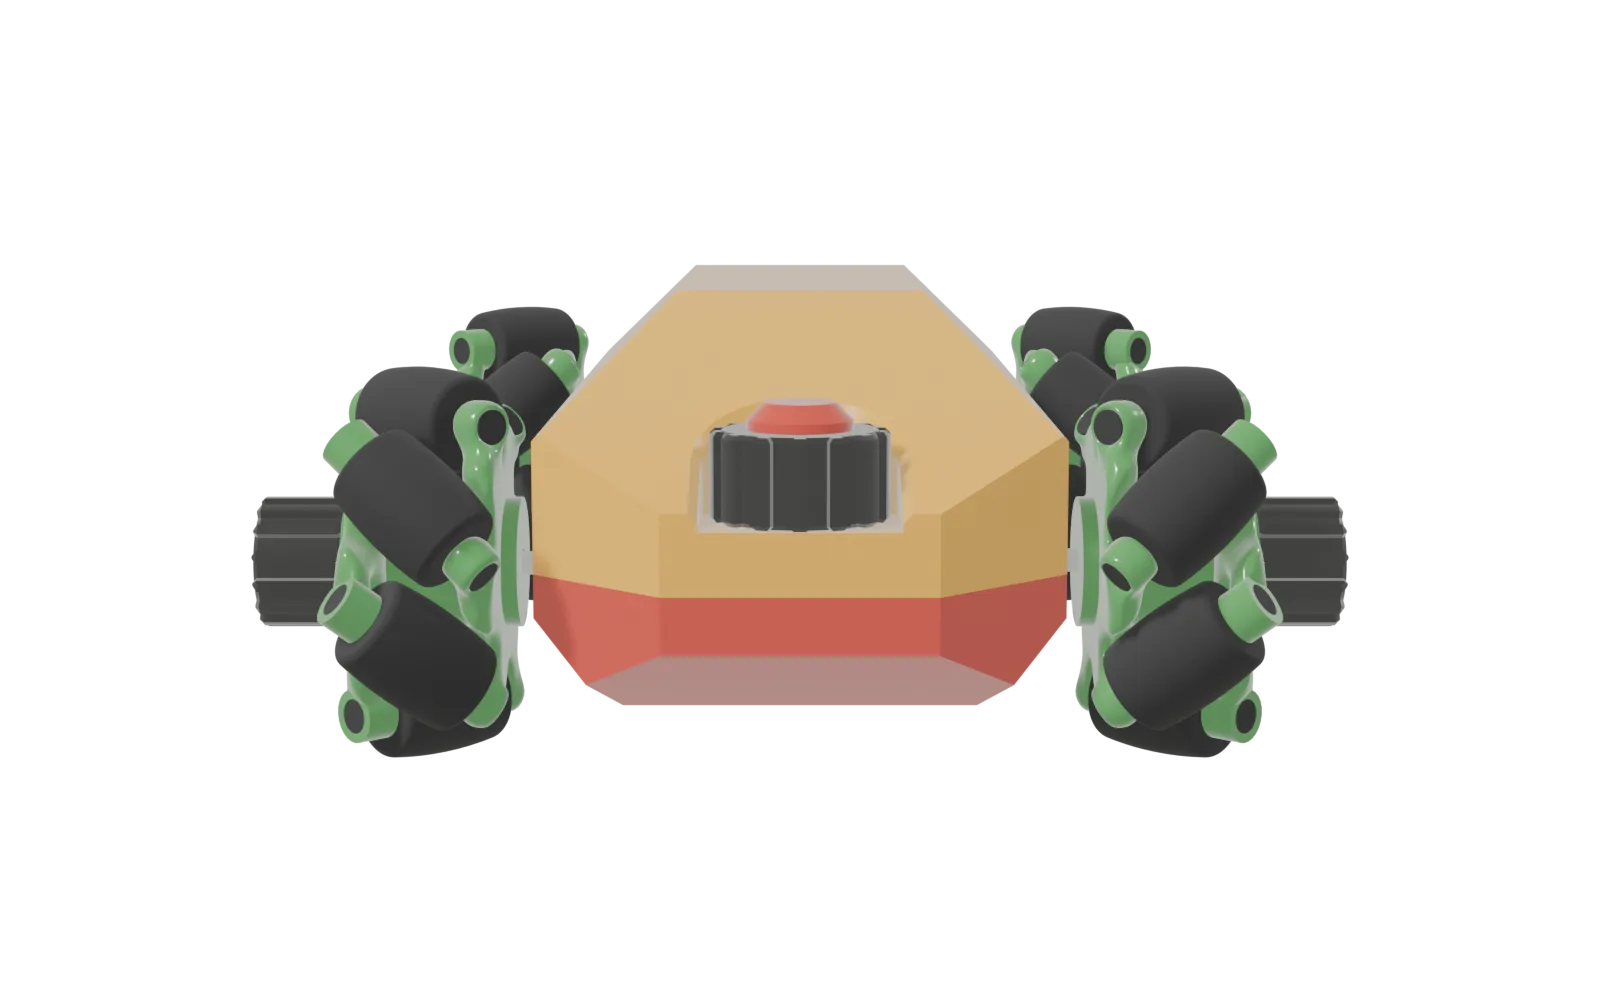
Inner and outer wheel halves hold the rollers at an angle to the axle. That is why the rover drives in every direction, sideways too.
What this part involves
- Create the sub-assembly and insert Innen1
- Insert Außen1
- Rigidly link the rim halves with an as-built joint
- Insert the nut and place it with a joint
-
03 / 05
FOUR MOTORS.FOUR WHEELS.
Every wheel has its own DC motor. Only this way can each wheel be controlled on its own, and the rover can turn on the spot.
-
04 / 05
SOLDERED.PROGRAMMED.
The Stern Didactic motor driver board with two L293D is soldered by the participants. An Arduino Nano 33 IoT turns the rover into a Wi-Fi access point: it is controlled with a virtual joystick on a smartphone.
What this part involves
- Practise the basic soldering technique
- Fit and solder slide switch S1
- Solder the 9 V snap connector, watch the polarity
- Fit both L293D, check the notch
-
05 / 05
FIVE DAYS.ONE VEHICLE.
In the Design & Make workshop the rover is built in five days: design, print, solder, program. The bundle with all parts costs 99.98 euros.
What this part involves
- Insert the base plate and ground it as the reference part
- Fit four DC motors with rigid joints
- Insert the PCB and combine it into a rigid group
- Fit the roof
Model: Autodesk Fusion, Stern Didactic. Taken over without simplification; what is hidden in Fusion is missing here too.
What it is about
Complete mechatronics training project: learners design all parts of a Mecanum rover in Autodesk Fusion (floor plate, housing, Mecanum wheels with angled passive rollers), 3D-print them, solder the Stern Didactic motor-driver PCB and program an Arduino Nano 33 IoT and control the rover via the Arduino Cloud (thing, cloud variables, dashboard); optionally as a variant via a Wi-Fi access point with a virtual joystick web server. 13 consecutive missions with tutorial videos, Fusion 3D models, technical drawings and quizzes.
General tolerance: DIN ISO 2768-m-K · Scale: 1:1
Learning objectives
- Distinguish and apply parametric and generative design
- Master core CAD operations in Autodesk Fusion: sketch, extrude, revolve, shell, mirror, circular pattern, thread
- Build assemblies using rigid and revolute joints
- Design and prepare parts for 3D printing
- Solder electronic assemblies safely
- Program microcontrollers (Arduino Nano 33 IoT) with cloud and access-point connectivity
- Understand omnidirectional Mecanum kinematics and implement them in control logic
Nullpunkt · The workshop in your browser
Apprentices also build this project virtually: 9 parts, on real machines, with the original drawings from Autodesk Fusion.
AI mentor
This project is available in the AI mentor as 13 missions, from getting started through the parts to the review. With a licence the AI mentor tailors the tasks to you.
The material is available as a ready kit in our shop.
This project is also available as a workshop: Design & Make
Whether a workshop, a class set or a completely new training project: we will find the right model.